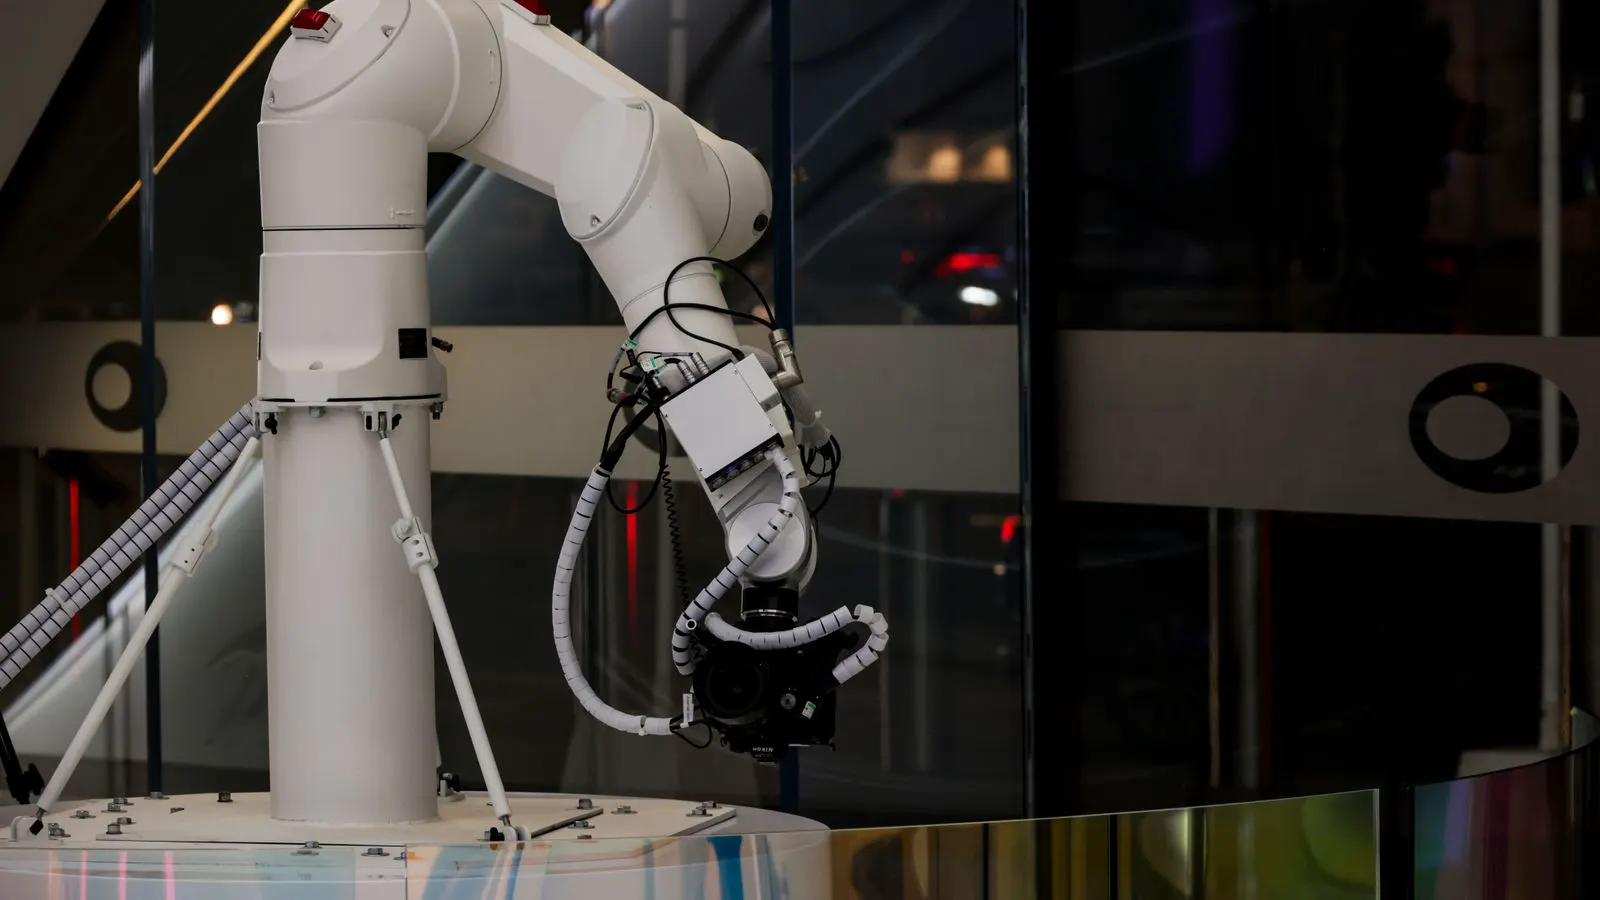
SCARA robots achieve sub-millimeter precision through rigid parallel-axis geometry, high-resolution rotary encoders, and real-time servo control. These factors reduce mechanical error and allow rapid motion without sacrificing repeatability.
- SCARA geometry keeps the payload axis vertical, which limits torque on the base and improves positional accuracy.
- High-resolution encoders and servo drives close the loop on positioning errors in real time.
- Rigid mounting and tooling design matter as much as the robot itself for final repeatability.
- Engineers should evaluate frame stiffness, control cycle rates, and end effector weight when specifying precision.
Why SCARA Robots Are Built for Precision
SCARA robots use two horizontal arms connected by a central vertical column. This structure creates a parallel-axis motion pattern that keeps the tool always pointing straight down. That orientation gives the system a mechanical advantage for small, fast movements in a flat work area.
The term SCARA stands for Selective Compliance in the Arm and Rotation Axis. The name reflects a specific design choice. The arms are stiff in the radial direction, where they must hold the tool in place. They are also compliant in the vertical direction, meaning the tool can move slightly up or down without adding load to the drive system. This separation of axes is the first reason SCARA systems can hold tight tolerances.
For engineers specifying a high-speed pick and place cell, this geometry is the starting point. The robot does not need to fight gravity with large vertical joints. It can spend its energy on horizontal motion and position holding.
How Parallel-Axis Motion Reduces Error
A parallel robot moves its tool along a path that is nearly parallel to the work surface. In a SCARA system, the X and Y axes define the tool position on the plane. The Z axis is a simple vertical lift.
This arrangement reduces error in two ways.
- The radial distance from the base to the tool is fixed by the arm length and joint angles.
- The tool tip stays on a flat plane, so vertical drift does not change the horizontal location.
Compare that with an articulated arm, where a small change in joint angle can move the tool tip in a direction that is not aligned with the work surface. The SCARA design keeps the error sources more predictable. When a control system commands a position, the mechanical response is closer to the command.
This predictability is why parallel robot designs are common in electronics assembly, where components must be placed in narrow sockets.
The Role of Rotary Encoders and Servo Drives
Precision is not just a mechanical property. It is a control problem. A SCARA robot uses rotary encoders on every joint. These sensors measure the actual position of each motor in electrical degrees or counts. The difference between the commanded position and the measured position is the error the controller must correct.
The resolution of the encoder determines how small a movement the controller can see. A high-resolution encoder gives the controller more information each cycle. The servo drive then adjusts the motor current to reduce that error.
The control cycle rate matters as much as the encoder resolution. A fast loop can react to disturbances, such as a sudden load change or a small mechanical flex, before the tool tip moves. For sub-millimeter accuracy, the controller must operate at a rate that keeps the error within the tolerance window.
When sourcing a SCARA robot, engineers should ask about the encoder resolution and the control cycle time. These two numbers tell you how well the robot can hold position under load.
Frame Stiffness and Mounting Effects
A robot is only as accurate as the structure that holds it. The base frame, column, and arm joints must resist deformation under load. If the frame flexes, the tool tip moves even when the joints report the correct angle.
This is where sourcing decisions get practical. A robot with a stiff aluminum frame may be lighter and cheaper, but it may not hold the same tolerance under a heavy tool. A steel frame is heavier but resists bending better. The choice depends on the tool weight and the required repeatability.
Mounting is the second factor. The base must be bolted to a surface that does not vibrate. A loose floor panel or a resonant table can add error that no encoder can fix. Engineers often use a dedicated machine base or a welded table. The ground connection matters too. Electrical noise on the motor cables can confuse the encoder signal.
In a worked example, consider a SCARA robot placing a small connector into a printed circuit board. The tool is light, but the board is flexible. If the robot base is mounted on a thin shelf that flexes when the robot moves quickly, the connector may land off-center. The fix is not a better robot. It is a stiffer mounting plate and a shorter, lighter cable.
Tooling and End Effector Design
The last part of the precision chain is the tool itself. The end effector holds the component and presents it to the work. If the tool is not rigid, the component can shift before release.
A simple pin gripper is stiff if the pin is short and the jaws are close to the component. A long suction cup is less rigid because the air cushion allows the part to tilt. A parallel gripper with long fingers can bend at the tips under load.
The tool center point must be known accurately. If the calibration assumes the tool tip is at the center of the suction cup, but the cup flexes, the real contact point is off. This error is fixed during setup but can return if the tool is replaced or the vacuum changes.
Engineers should specify the tool weight and the tool center offset in the robot configuration. The robot controller can compensate for the weight, but it cannot compensate for a tool that changes shape.
How Precision Affects Sourcing Decisions
When buying a SCARA robot for a precision cell, the spec sheet is not enough. The final accuracy comes from the whole system. The table below shows the main factors and what to check.
| Factor | What to Check | Why It Matters |
|---|---|---|
| Joint Encoders | Resolution and type | Higher resolution gives the controller more data to correct error |
| Frame Material | Aluminum or steel | Stiffer frames reduce flex under load |
| Mounting Surface | Rigidity and vibration | A stable base prevents external error sources |
| Tool Design | Stiffness and center point | A rigid tool keeps the part aligned during release |
| Control Cycle | Loop rate and response | Fast loops correct disturbances before the tool moves |
The trade-offs are real. A steel frame is more expensive and heavier. A high-resolution encoder increases the cost of the drive. A stiff mounting base may require a new floor structure. Each choice moves the final accuracy. The goal is to spend where the error is largest, not on every option.
A Worked Example in Plain Words
Imagine a production line that places a small sensor onto a metal bracket. The bracket has a hole that is tight. The sensor must land within a small margin.
The SCARA robot lifts the sensor with a small gripper. The robot moves to the bracket. The gripper lowers the sensor. The part drops into the hole.
If the robot base is loose, the whole arm shifts a tiny amount during the move. The sensor lands off-center. If the gripper fingers are long, they bend when they close. The sensor tilts. If the encoder resolution is low, the controller does not know the joint moved a few counts too far.
The fix is to use a stiffer base, a shorter gripper, and a robot with a faster control loop. The robot geometry already handles the parallel motion. The rest is about removing the error sources that sit outside the robot.
Final Checklist for Engineers
Before signing off on a SCARA robot for a precision task, run through these points.
- The required tolerance is measured from the tool tip, not the joint axis.
- The tool weight is known and included in the robot load calculation.
- The mounting surface is rigid and free from vibration.
- The encoder resolution and control cycle are specified in the purchase order.
- The tool center point is calibrated and recorded.
A sub-millimeter SCARA system is not magic. It is a set of mechanical and control choices that add up. When each part is chosen for stiffness, resolution, and stability, the tool tip does what it is told.
Frequently asked questions
What is the main reason SCARA robots are accurate?
Their parallel-axis geometry keeps the tool on a flat plane and reduces the effect of joint error on horizontal position.
Can a cheap mounting surface ruin a high-precision SCARA setup?
Yes. If the base flexes or vibrates, the tool tip moves even when the joints are perfectly controlled.
Does a heavier tool always make a SCARA less accurate?
It can. Heavier tools increase the load on the joints and the tooling, which can cause more flex and require a stiffer frame.
What is the difference between encoder resolution and control cycle rate?
Encoder resolution is how finely the position is measured. Control cycle rate is how often the controller checks and corrects that position.
Is a parallel robot always better than an articulated arm for precision?
Not always. SCARA and other parallel robots are best for flat, high-speed tasks. Articulated arms handle more complex paths but have different error patterns.